Embodied AI (EAI) Lab
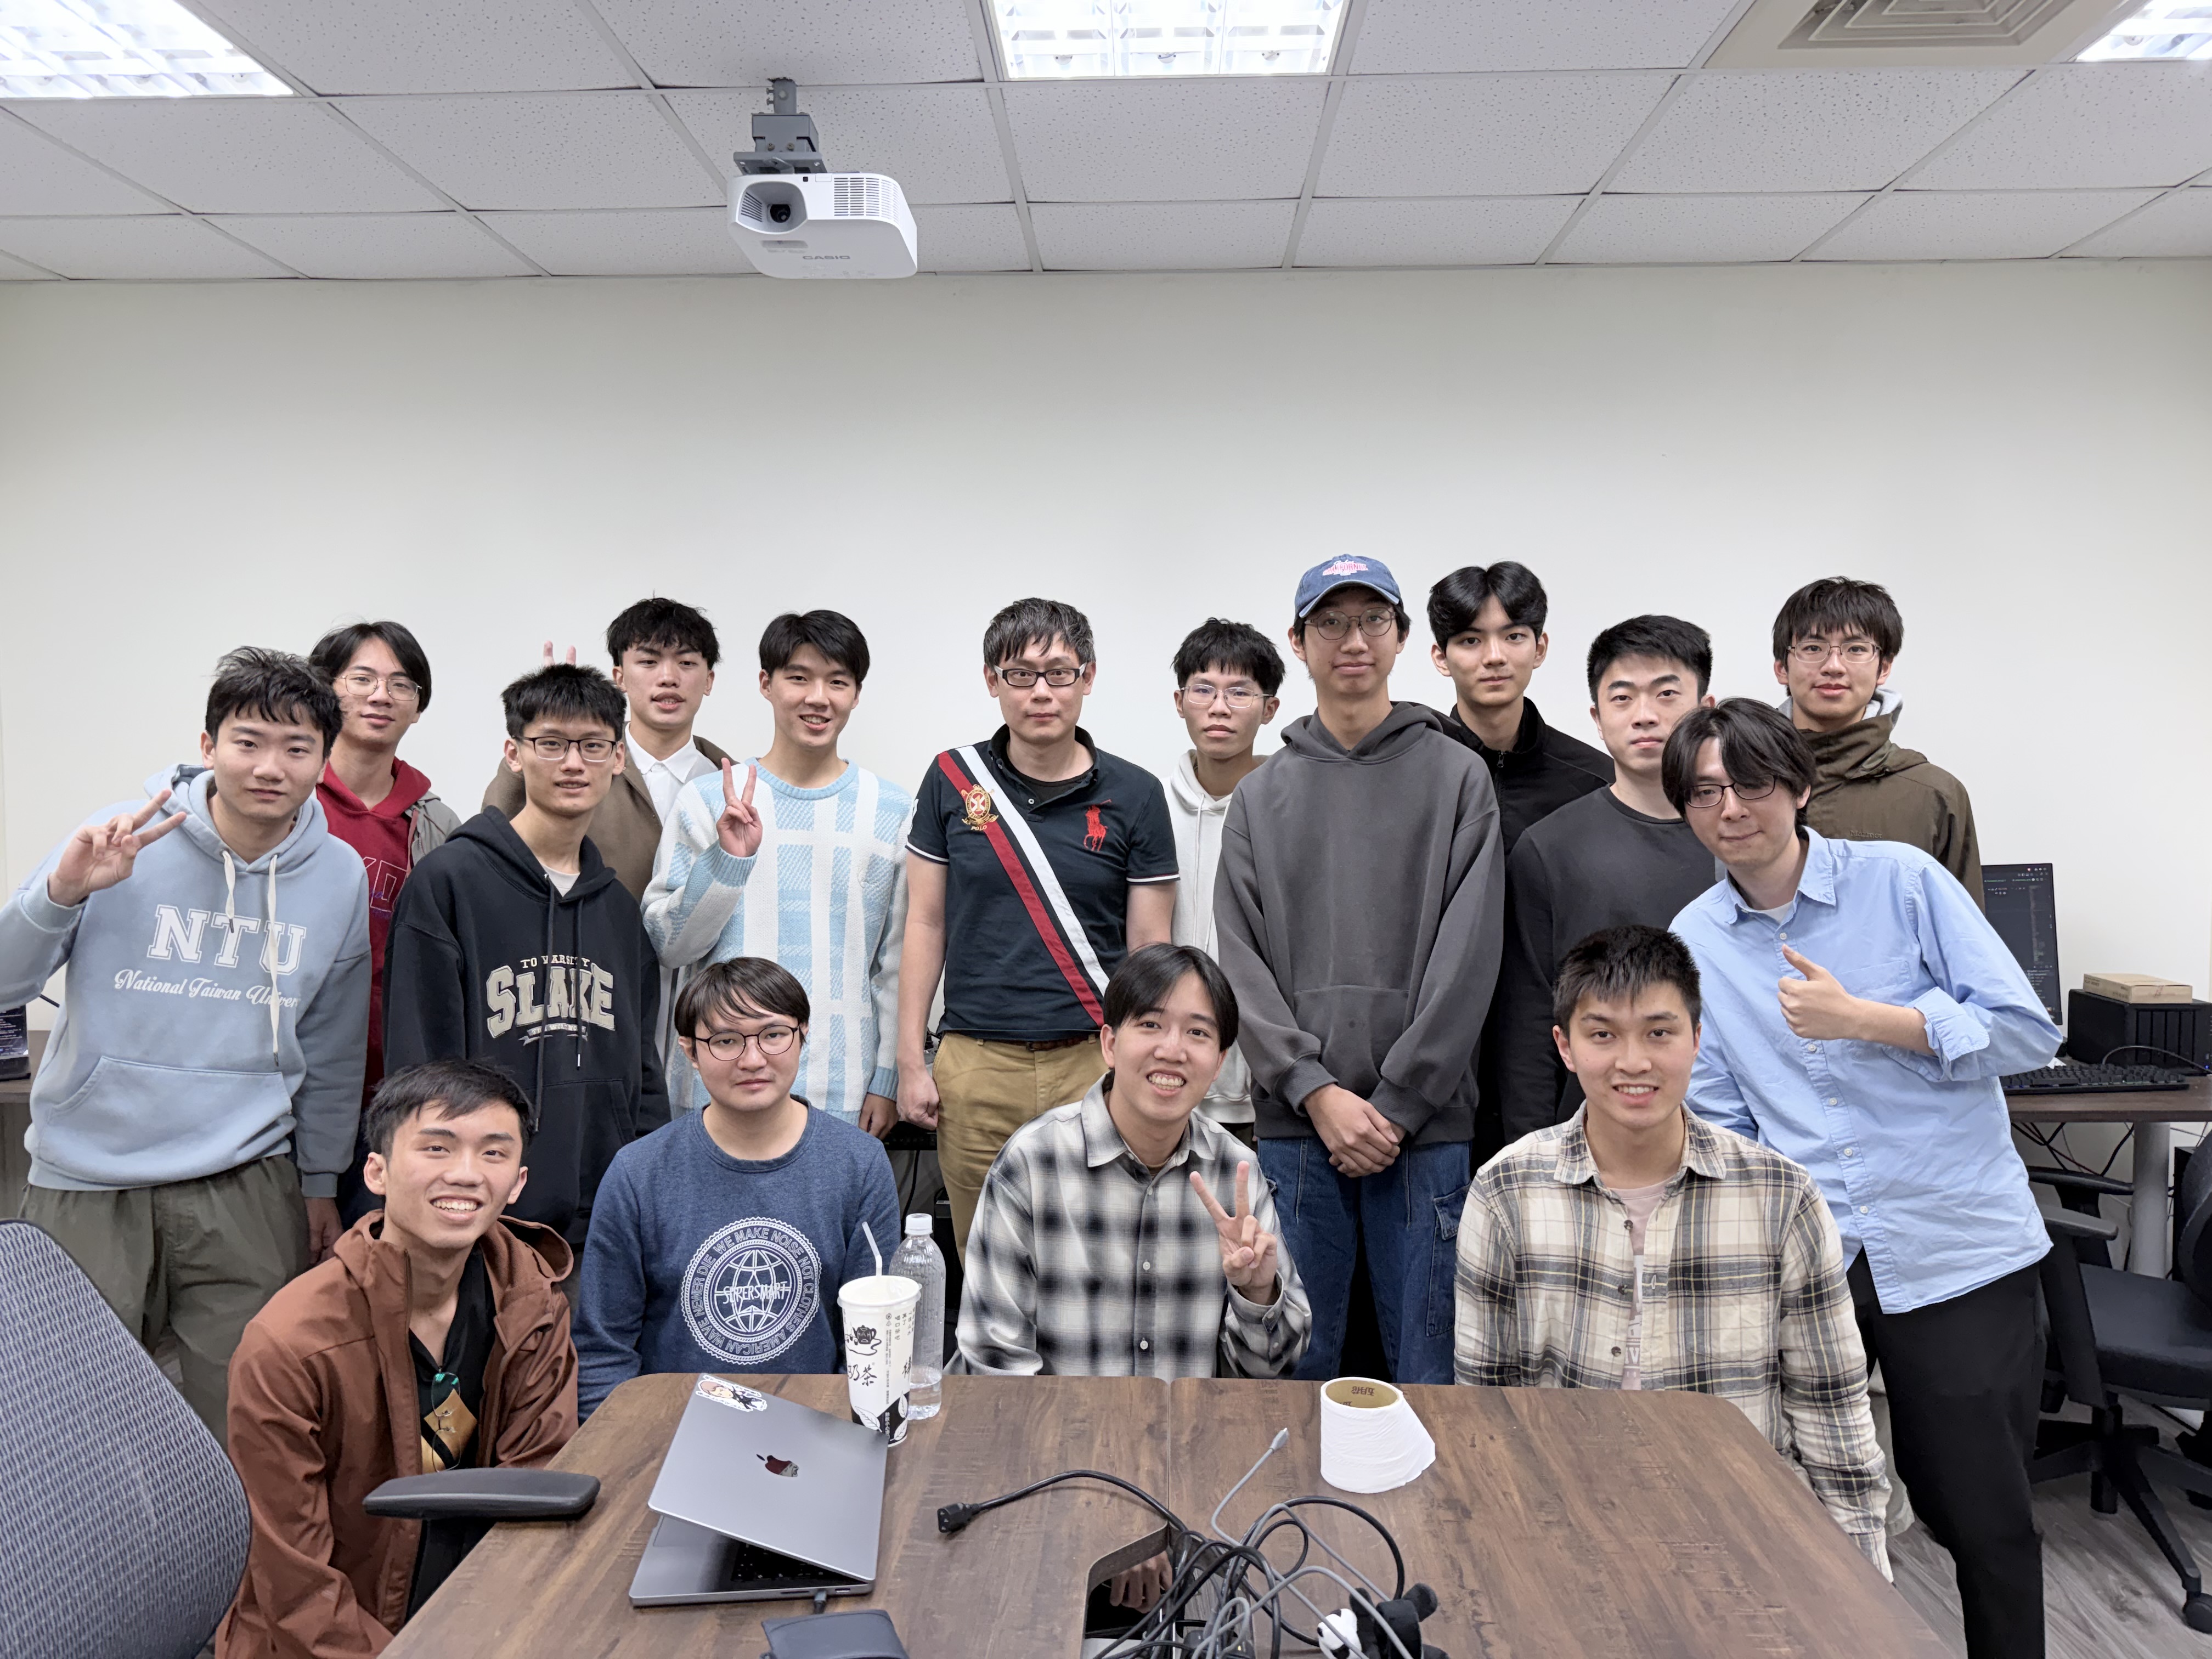
Welcome! The Embodied AI lab are dedicated to developing autonomous, real-world robotic systems. We approach this challenge from three perspectives. The first is Action Control. We train robot policies that allow robots to perform mobile manipulation tasks with high efficiency, effectiveness, and robustness. The second is Learning and Exploration. We develop algorithms that enable physical agents to explore their environments and continually acquire new skills with minimal human intervention. The third is Dynamic Modeling. We build dynamic systems that enhance environmental understanding by simulating the outcomes of physical interactions. Together, these three research topics aim to create robots that function as intelligently as animal beings.
Code for our projects is available at https://github.com/EmbodiedAI-NTU.
We are looking for Ph.D/Master/undergraduate students interested in robot learning, computer vision, and machine learning. If you are an undergraduate at NTU interested in research positions, please fill out this form. If you are interested in Master/Doctoral positions, please fill out this form.
Recent Publications (∗ Equal contribution. † Corresponding author.)
-
Learning Conditional Source Distribution via Flow Reversal for Temporal Flow Matching
In submissionarXiv / Code / Project Page
-
Task Inference Beyond Least Squares in Behavioral Foundation Models
1National Taiwan University, 2National Yang Ming Chiao Tung UniversityIn submissionarXiv / Code / Project Page
-
TaRL: Learning General and Physical Rewards from Tactile Demonstrations
1National Taiwan University, 2Delta ElectronicsArXiv 2026arXiv / Code / Project Page
-
COT-FM: Cluster-wise Optimal Transport Flow Matching
CVPR 2026
-
DexMan: Learning Bimanual Dexterous Manipulation from Human and Generated Videos
1National Taiwan University, 2Stanford UniversityArXiv 2025
-
Information Seeking for Robust Decision Making under Partial Observability
1National Taiwan UniversityArXiv 2025
People
Professor
 Tsung-Wei Ke
 Li-Xuan Peng
 Ruei-Jia Huang
Undergraduate Students
 Kuan-Hsun Tu
(杜冠勳) Chien-Sheng Chiang
(江建陞) Jhen Hsieh
(謝震) Chun-Yang Cheng
(鄭峻揚) Wei-Lun Hsiao
(蕭葦倫) Daisy Yuhsin Huang
(黃予星) Hsuan-Chi Liu
(劉軒齊)
- Yen-Hsiang Chen
(陳彥翔) - Li-Chen Kao
(高立辰) - Dian Cheng
(鄭琠) - Hsin-Wei Chen
(陳忻韋) - Yu-Tsen Tsai
(蔡侑岑) - We-Hsiang Chiu
(邱威翔) - Po-Ke Fan
(范柏格) - Cheng-Ting Tsai
(蔡政廷)
Alumni
- Pang-Chi Lo
(羅邦齊) - Jhao-Hsun Lai
(賴昭勳) - Djengo Cyun-Jyun Fang
(方群鈞) - Po-Yi Wu
(吳柏毅)